 Return to the range "Automation, Control & Process"
Franka Emika Research and Production 3 Robot
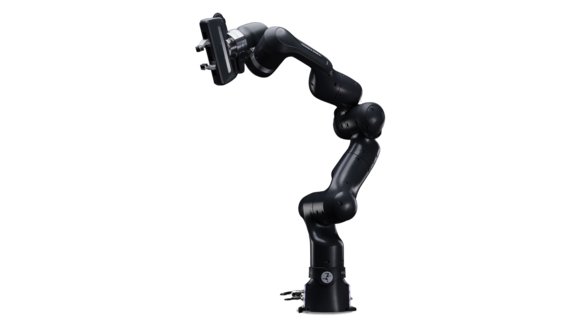
The Franka Emika 7-axis collaborative robot
Doc. commercial Eng
 Datasheet Robot Franka Emika Production 3
Doc. commercial Fr
Site Internet
 Franka Emika
Vidéo
Related ranges :
The Franka Emika 7-axis collaborative robot
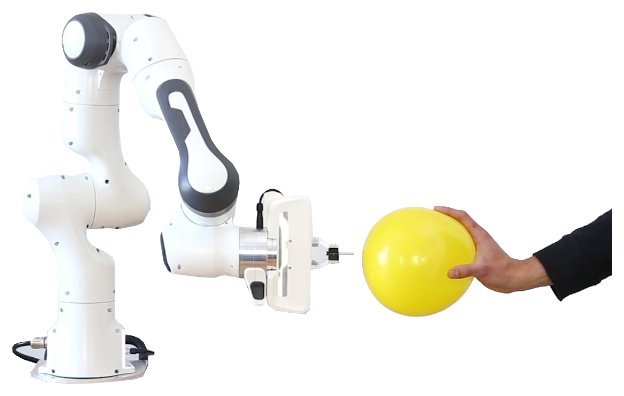
Franka Emika's robot is agile and sensitive like a human arm, with seven axes, each equipped with a force sensor.
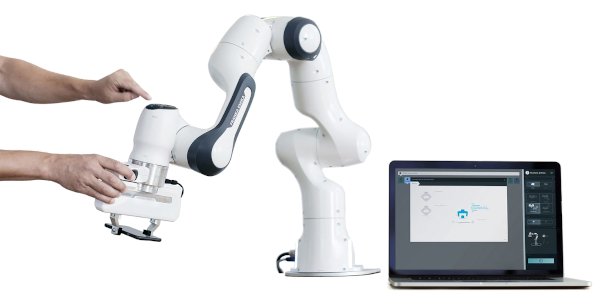
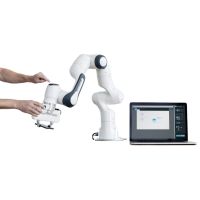
Programming is intuitive and based on workflows, and interaction is seamless.
The system features a user-friendly interface based on apps—encapsulated robot programs. Organize the apps into a sequence. Then teach the robot by demonstration and adjust the parameters.
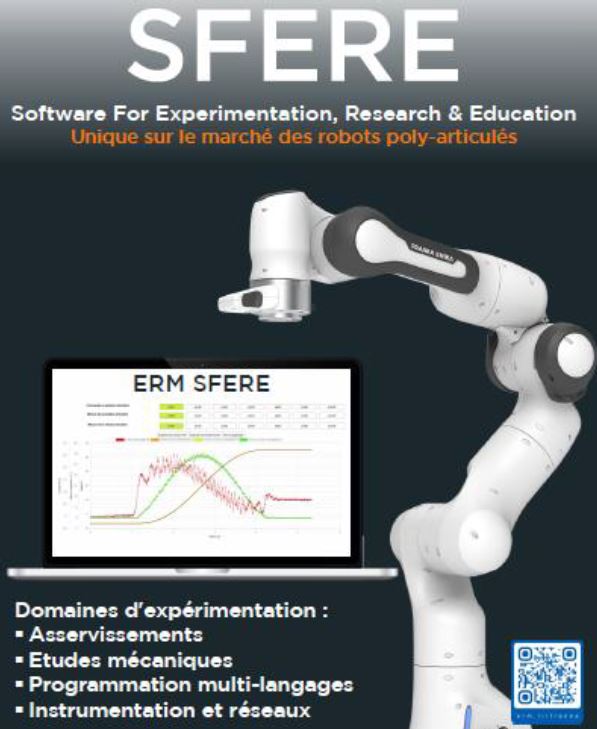
The suite of software dedicated to research and academia makes it a unique tool on the market.
Load and geometry: 855mm radius – 94.5% volume coverage – 3kg load
Movement: Repeatability +/-0.1mm – Path deviation +/-1.25mm
Force measurement sensitivity: Resolution < 0.05N – Accuracy 0.8N – Repeatability < 0.05N
Force application: Minimum controllable force 0.05N at 1kHz
Interaction: Guide force 2N – Collision detection time < 2ms – Nominal collision response time < 50ms
Position encoders: Resolution 14 bits – Absolute position – Redundancy in connections
Electronic connections: 1kHz communication bus – Highly integrated
Brushless DC motors: High efficiency – No maintenance over lifetime – High speed
Deformation wave gears: High-quality gears (made in Germany) – Excellent positioning accuracy and repeatability
Crossed roller bearings: Robust throughout the robot's lifetime – Lightweight design – High rigidity
Force sensors: 13-bit resolution – Excellent accuracy – High sensitivity
FR//Franka3Research-Std: Franka 3 Research Pack for the Franka 7-axis collaborative robot (855 mm radius - 3 kg payload) with: 7-axis robot and controller - 2.5 m Type F power cable - 2-finger collaborative gripper - Franka Control Interface FCI3 - DESK graphical programming interface - Prototyping/Research application package - RIDE application development environment
FR//Franka3Production-Std: Franka 3 Production package for the Franka 7-axis collaborative robot (855 mm radius - 3 kg payload) with: 7-axis robot and controller - 2.5 m Type F power cable - 2-finger collaborative gripper - DESK graphical programming interface - Production application package - RIDE application development environment
FE02: Shmalz vacuum gripper with vacuum generator for Franka Panda 7-axis collaborative robot with vacuum gripping application pack
FE03: 16E/16S Modbus remote module for Franka Panda robot (Industry Pack)
FE11: Option: Set of two laser scanners for safe movement speed management, for Franka Cobot Station
FE12: Option: Visor Robotic V10 monochrome 2D vision kit (Brand: Sensopart) for Franka collaborative robot
FE13: Option: Visor Robotic V20 color 2D vision kit (Brand: Sensopart) for Franka collaborative robot
RK11: Option Parts for robotic clipping and gluing simulation projects
RK12: Option Parts for 2D bulk handling and pick-and-place projects