 Return to the range "Automation, Control & Process"
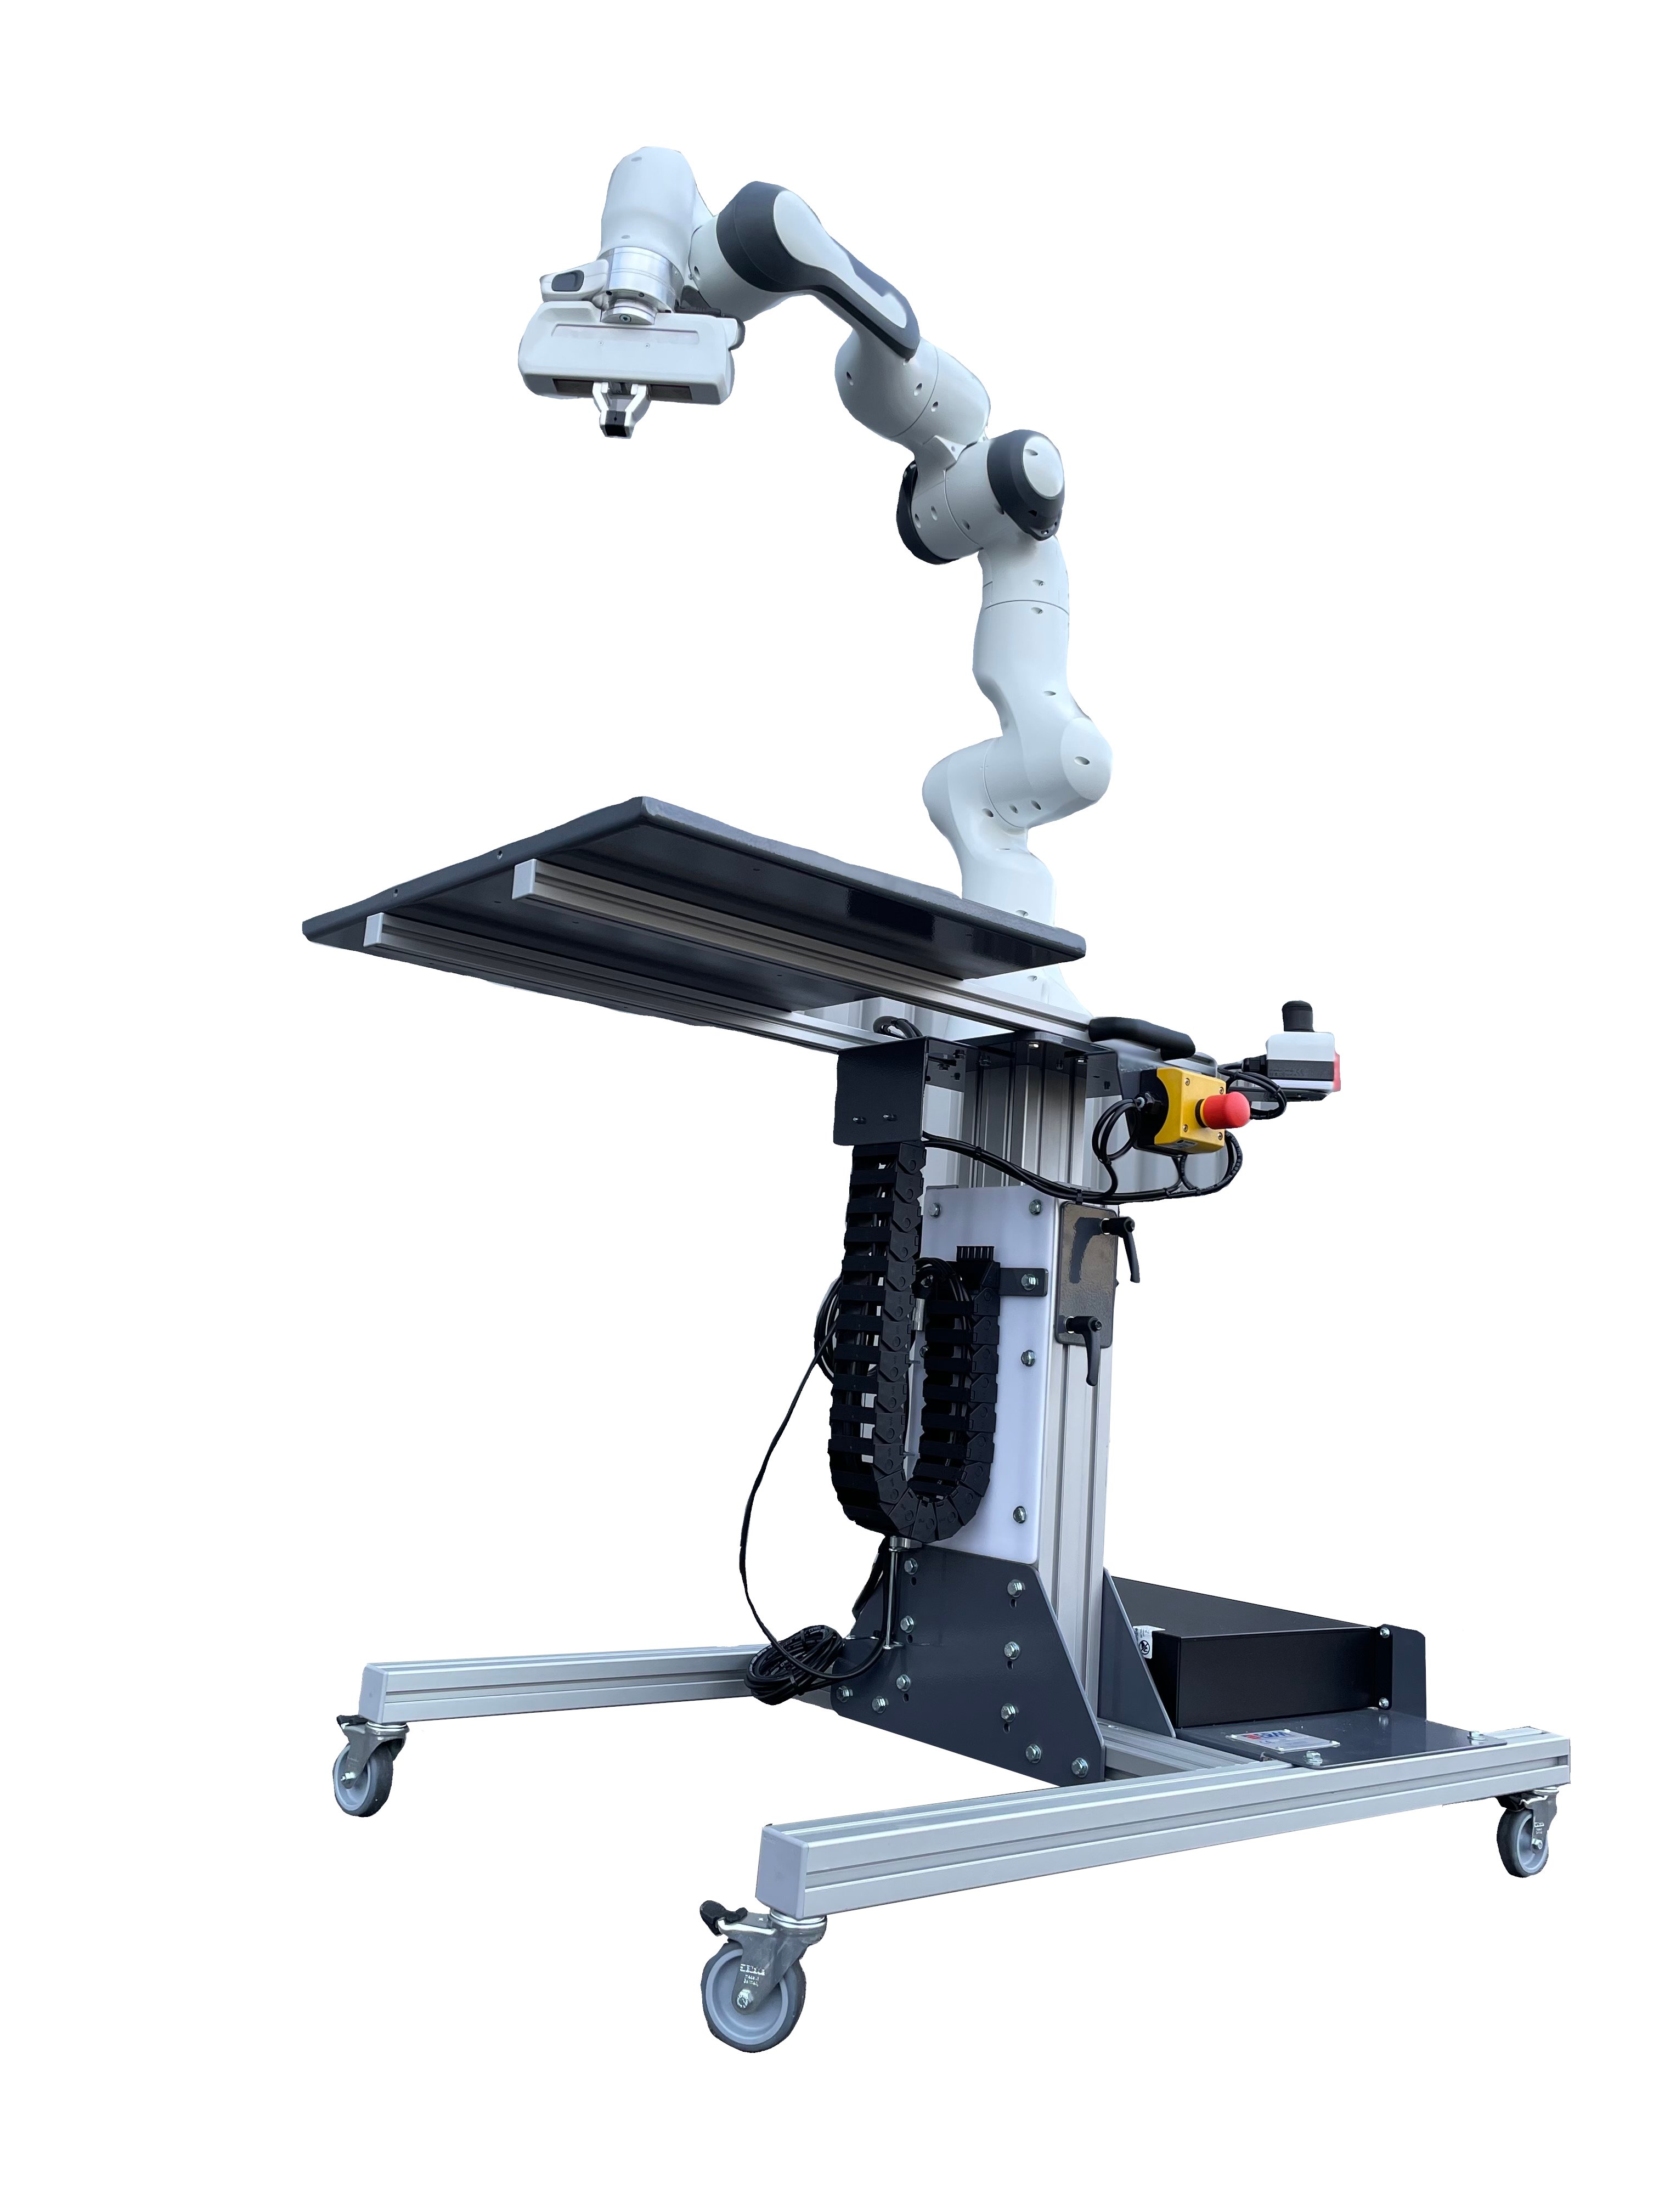
Franka Cobot & Vision Station
Doc. commercial Eng
 Brochure Robot de Franka
Doc. commercial Fr
Site Internet
 Franka Emika
Vidéo
Related ranges :
Industrial teaching system for implementing a Franka Emika 7-axis collaborative robot
Customization of jars/bottles by placing a lid on them
Learning collaborative robotics
Programming the Franka Emika 7-axis robot (855 mm radius, 3 kg load)
Suction cup and autonomous vacuum generator on board
Modbus TCP communication
Repeatability +/- 0.1 mm
Guiding force ~2 N
800 mm wide chassis to fit through all doors
Open system with set of 2 safety sensors (optional)
Discovering and learning how to use the system
Studying a robotic workstation, ergonomics, robot and actuator sizing, etc.
Commissioning and validating operation
Adjustment and configuration of the various components
Robot programming
Learning collaborative robotics
Programming of Franka Emika 7-axis robot (radius 855 mm, load 3 kg)
Numerous features: arm, control, applications, community, FCI, pilot, hand, office
Library of business applications (options)
FE10: Franka Cobot & Vision Station: Franka Emika 3 Research 7-axis collaborative robot (855 mm radius - 3 kg payload) on mobile chassis with collaborative gripper, work tray, and Research application pack
FE01: Franka Emika collaborative electric gripper (70N max force, 80mm stroke, interchangeable fingers)
FE02: Shmalz vacuum gripper (with integrated vacuum generator)
FE03: 16E/16S Modbus remote module for the Franka Panda robot (Industry Pack)
RK12: Parts for 2D bulk handling and pick-and-place projects